World Sandbox · engineering journals · 2026

Worlds rebuilt, generated and measured

Experiments with world models and 3D reconstruction: turning video into maps, generating worlds for robots, and opening each pipeline up stage by stage. Every journal shows what each stage produced, with the data to replay it.
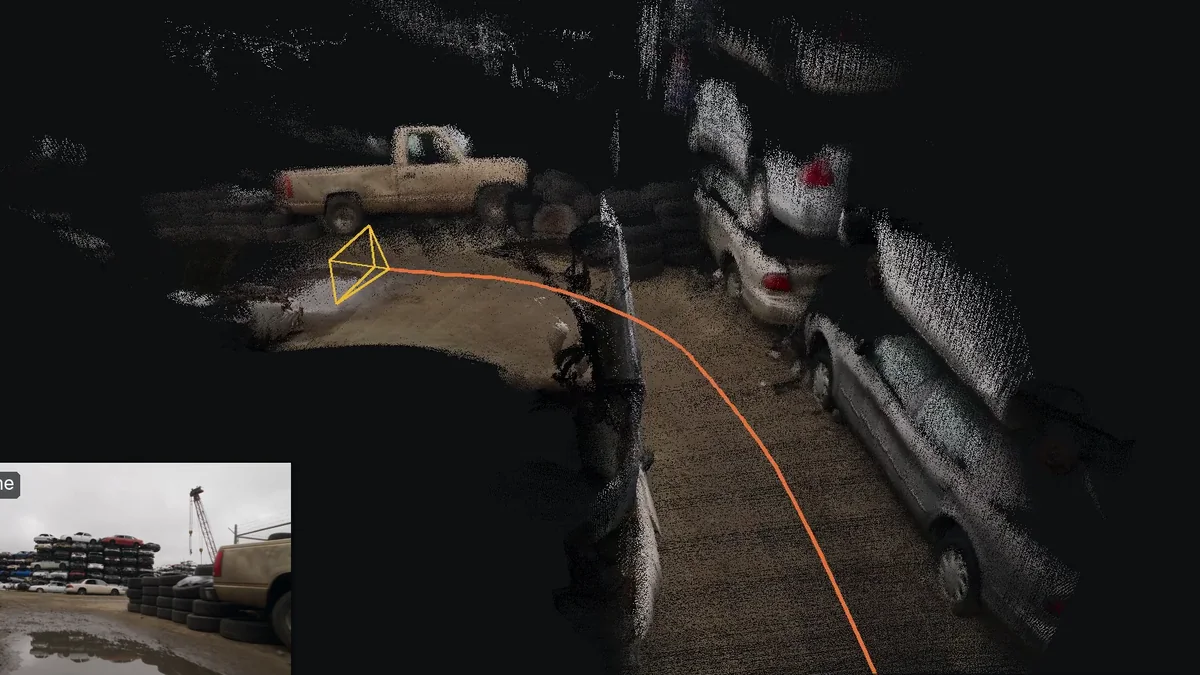
SLAM · Depth Anything 3 · RTX 4090

Synthetic SLAM

Six seconds of generated robot video become a camera path and a 3.33 M-point map in 20.6 s, with every stage of AMB3R-SLAM opened up and replayable in 3D.

SLAMfeed-forward 3Dgenerated video3D viewer

Read the journal →